Spatial maths blocks
- class Tr2Delta(**blockargs)[source]
Bases:
FunctionBlockTR2DELTA
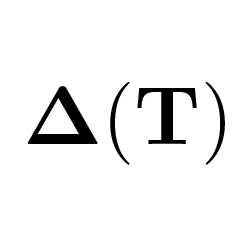
Transforms to delta
- Inputs:
2
- Outputs:
1
- States:
0
Port type
Port number
Types
Description
Input
0
SE3
\(\mathbf{T}_1\) pose.
Input
1
SE3
\(\mathbf{T}_2\) pose.
Output
0
ndarray(6)
\(\Delta\)
Difference between \(\mathbf{T}_1\) and \(\mathbf{T}_2\) as a 6-vector
See also
- __init__(**blockargs)[source]
- Parameters:
blockargs (
Any) – common Block options
- class Delta2Tr(**blockargs)[source]
Bases:
FunctionBlockDELTA2TR
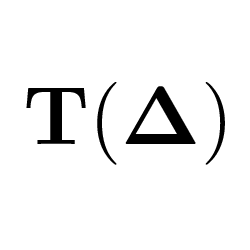
Delta to transform
- Inputs:
1
- Outputs:
1
- States:
0
Port type
Port number
Types
Description
Input
0
ndarray(6)
\(\Delta\)
Output
0
SE3
\(\mathbf{T}\), pose.
6-vector spatial displacement to transform.
See also
- __init__(**blockargs)[source]
- Parameters:
blockargs (
Any) – common Block options
- class Point2Tr(T=None, **blockargs)[source]
Bases:
FunctionBlockPOINT2TR
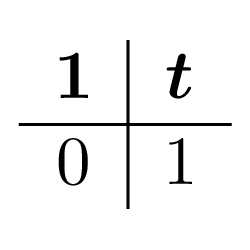
Point to transform.
- Inputs:
1
- Outputs:
1
- States:
0
Port type
Port number
Types
Description
Input
0
ndarray(3)
\(\mathit{p}\), point.
Output
0
SE3
\(\mathbf{T}\), pose.
The parameter
Tis an SE3 object whose translation part is replaced by the input- __init__(T=None, **blockargs)[source]
- Parameters:
T (
Any) – the transformblockargs (
Any) – common Block options
If
Tis None then it defaults to the identity matrix.
- class TR2T(**blockargs)[source]
Bases:
FunctionBlockTR2T
Translation components of transform
- Inputs:
1
- Outputs:
3
- States:
0
Port type
Port number
Types
Description
Input
0
SE3
\(\mathit{T}\) transform.
Output
0
float
\(x\) component of translation.
Output
1
float
\(y\) component of translation.
Output
2
float
\(z\) component of translation.
See also
- __init__(**blockargs)[source]
- Parameters:
blockargs (
Any) – common Block options